
1st Place in Logistics Picking - 2nd What Bimanuals Can Do (WBCD 2026) CompetitionICRA 2026, Vienna
Jun 2026
I am an MSc CS (Robotics and AI) student at McGill University as a McCall MacBain Scholar, working at the Mobile Robotics Lab under the supervision of David Meger.
Before McGill, I received my Bachelor's degree in Mechatronics Engineering from the Pontifical Catholic University of Peru (PUCP) in 2025, with an exchange semester at the University of Texas at Austin. I interned at BSH Home Appliances and worked as an AI Research Engineer at EsSalud, where I led health-AI projects. Along the way, I co-founded Outliers, a Software and AI Consultancy for SMBs, and NONHUMAN, one of LATAM's first robot learning labs.
I am excited about startups, autonomous robots, and the future of humanity in space.
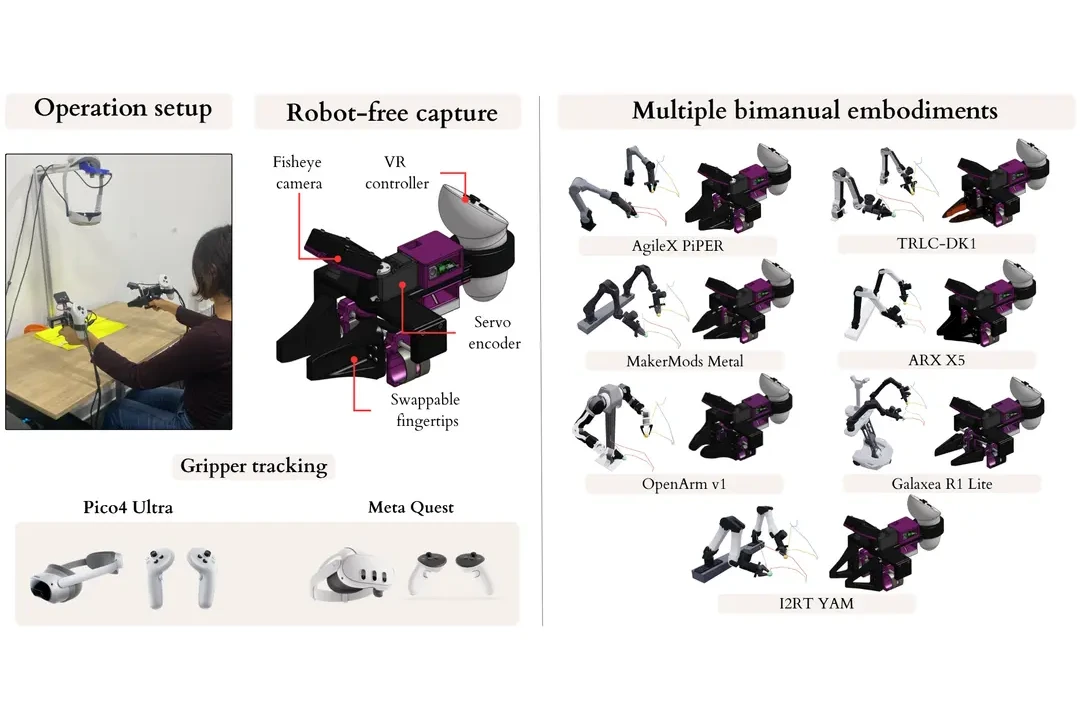
Hand-worn interface whose parallel jaws carry swappable fingertips shaped like the robot's own gripper, so demonstrations transfer without changing the robot. 562 robot-free towel-folding demonstrations trained ACT (12/20) and fine-tuned π0.5 (7/20) on PiPER arms. A pair costs USD 557 with a Quest 3S. All open source.

Experimental testbed and benchmark for evaluating imitation learning architectures on autonomous dump pocket cleaning. Benchmarks four IL architectures (ACT, Diffusion Policy, π0.5 model, and SmolVLA) using a SO-ARM100 platform with granular bentonite material.

The NONHUMAN team built an ALOHA-style bimanual manipulator using Piper arms, achieving a system 4x cheaper than Stanford's original ALOHA. I led the mechanical design and developed the teleoperation and data-collection stack. The team collected 3,000+ pick-and-place episodes (2,301 curated and available on HuggingFace) to fine-tune and test the π0.5 model.
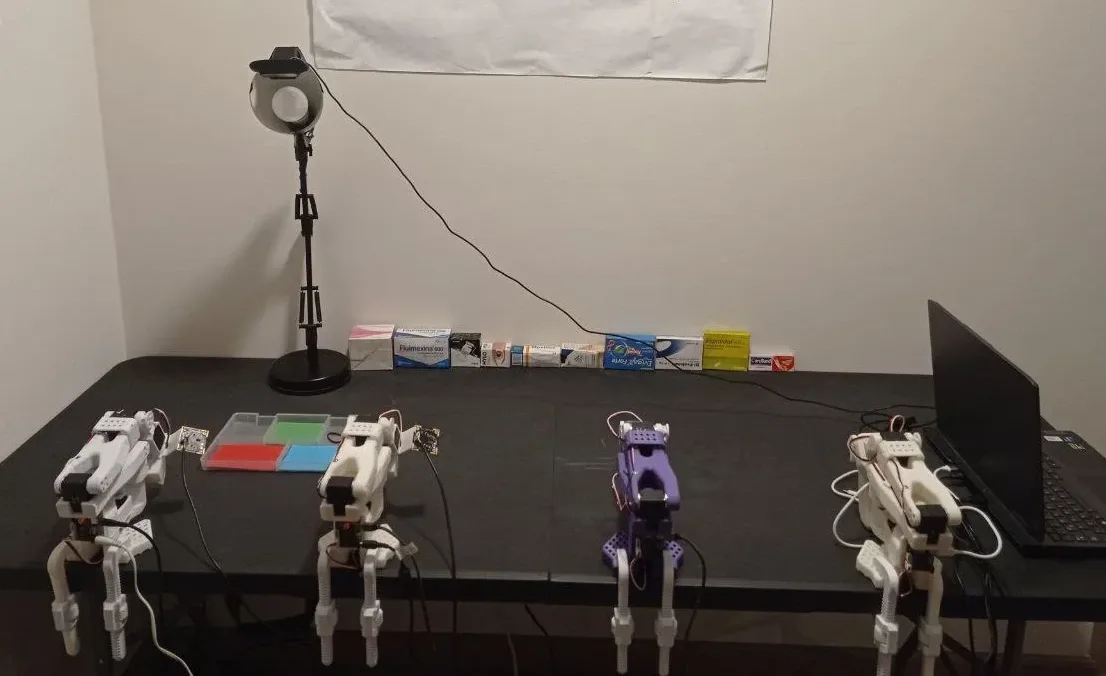
A pilot study conducted at IETSI-EsSalud evaluating a low-cost bimanual robotic system (12 DOF) based on the open-source SO-ARM100 project. The system was trained via Imitation Learning and tested on a sample of 10 medication box types, achieving an 80% global success rate in a controlled environment.

Modular mechatronic system for automated package classification using barcode detection and independent sorting modules. Designed to reduce space requirements while maintaining scalability.

Co-led the company end to end, generating five figures in revenue while studying and working full-time. Helped 20+ SMEs across the USA, AU, EU, and LATAM improve their online presence and efficiency through tech and AI.

Started with a bimanual SO-ARM100 setup in early 2025, then raised angel funding to build one of LATAM's first student-led robot learning labs (15+ members, 5 universities). With part of the team, won 1st Place in Logistics Picking at the WBCD Competition, ICRA 2026 (Vienna).
MSc CS student as a McCall MacBain Scholar.

GPA: 17/20 (Peruvian scale). Top 2% in faculty; #1 in Mechatronics during the 2021–22 period.

University Honors (Spring 2023). Courses: Innovation/Entrepreneurship, Spacecraft Dynamics, Materials Engineering & Lab, Mechatronics Lab, and Galaxies/Quasars/Universe.
Conducted lab sessions and supervised graded quizzes:

Institute for Health Technology Assessment and Research (IETSI), EsSalud
Feb 2025 – Aug 2025
Led 4 pilots (NutriBot, MediVoz, RADOX and BISO ARM-100); presented at Peru's 2025 Health-AI Congress. Pilot results: NutriBot scored 78.9/100 SUS, 85% improved diets; MediVoz reduced note-taking time by 70%.

Redesigned stove grill, projected to save $54k/year; reworked hinge system to reduce cost by $0.50 per unit.